#include <VehPoseSource.h>
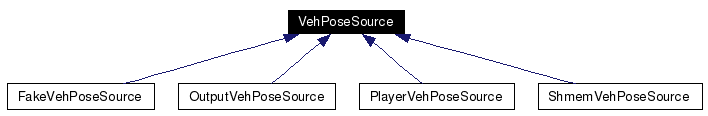
Inheritance diagram for VehPoseSource:
Public Member Functions | |
| virtual | ~VehPoseSource () |
| Empty virtual destructor for VehPoseSource. | |
| virtual bool | getPose (utils::Time time, VehPose &pose)=0 |
| Get the vehicle pose at a given time. | |
| virtual bool | getCurPose (utils::Time &time, VehPose &pose, bool blocking=0) |
| Get the current vehicle pose. | |
Static Public Member Functions | |
| static void | interpolate (const VehPose &prev_pose, const VehPose &next_pose, double t, VehPose &sensor_pose) |
| Convenience routine for interpolating between and extrapolating sensor poses. | |
| static const char * | intfName () |
| Get the interface name. | |
| static VehPoseSource * | create (const char *spec, utils::SymbolTable *globals=(0L)) |
Create interface from string if not in symbol table already, put in symbol table afterwards under intfName()+Intf. | |
| static VehPoseSource * | create (utils::ConfigFile ¶ms, utils::SymbolTable *globals=(0L)) |
Create interface from file if not in symbol table already, put in symbol table afterwards under intfName(). | |
| static VehPoseSource * | interface (const char *spec, utils::SymbolTable *globals=(0L)) |
| Create interface from string if not in symbol table already. | |
| static VehPoseSource * | interface (utils::ConfigFile ¶ms, utils::SymbolTable *globals=(0L)) |
| Create interface from params if not in symbol table already. | |
| static VehPoseSource * | generate (const char *spec, utils::SymbolTable *globals=(0L)) |
| Create interface from string. | |
| static VehPoseSource * | generate (utils::ConfigFile ¶ms, utils::SymbolTable *globals=(0L)) |
| Create interface from a parameter file. | |
| static VehPoseSourceGenerator * | generator (utils::SymbolTable *globals) |
| Get the interface generator. | |
| static VehPoseSource * | getIntf (utils::SymbolTable *globals) |
Get the last result of create. | |
| static void | clear (utils::SymbolTable *globals) |
| Clear the interface out of the symbol table. | |
An abstract interface to 3D road information given by an STL vector of 3D points
Definition at line 22 of file VehPoseSource.h.
|
|
Empty virtual destructor for VehPoseSource. For C++ syntax reasons, it is a good idea to explicitly define a virtual destructor, even if empty like this one, to any abstract class like this. Definition at line 28 of file VehPoseSource.h. |
|
||||||||||||||||
|
Get the current vehicle pose. Returns the latest vehicle pose along with the time at which it was collected. The call can be blocking, i.e., we block until the next unread vehicle pose is acquired, but it is usually polling, i.e., it returns immediately with the most recent vehicle pose
Reimplemented in OutputVehPoseSource, PlayerVehPoseSource, and ShmemVehPoseSource. Definition at line 10 of file VehPoseSource.cc. References getPose(). Referenced by OutputVehPoseSource::getCurPose(). |
|
||||||||||||
|
Get the vehicle pose at a given time. Returns the vehicle pose at the given time. The implementation will attempt to interpolate or extrapolate from known poses to get the pose at the desired time.
Implemented in FakeVehPoseSource, OutputVehPoseSource, PlayerVehPoseSource, and ShmemVehPoseSource. Referenced by getCurPose(), and OutputVehPoseSource::getPose(). |
|
||||||||||||||||||||
|
Convenience routine for interpolating between and extrapolating sensor poses. Takes prev_pose and next_pose, and then interpolation factor t, where t=0 means prev_pose and t=1 means next_pose, and puts interpolated result in sensor_pose. If t > 1, then we do an extrapolation.
Definition at line 16 of file VehPoseSource.cc. References VehPose::ori, and VehPose::pos. Referenced by VehPosePlayer::getPose(), and ShmemVehPoseSource::interpolate(). |
 1.4.4